Content:
Title: Stop the Wobble: A Linux Geek’s Guide to PID Tuning
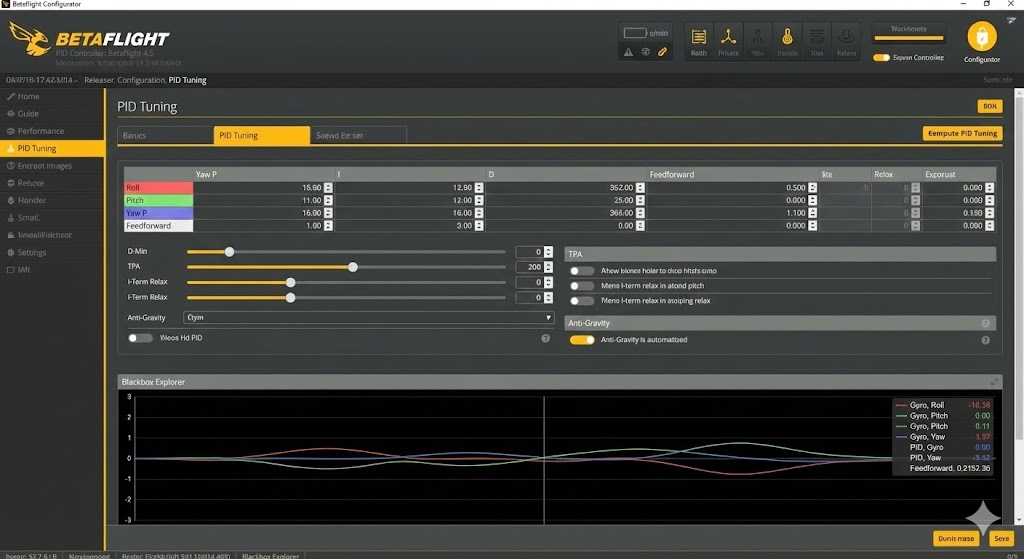
Opening the "PID Tuning" tab in Betaflight is terrifying for most pilots. It looks like advanced calculus. But you don't need a math degree to get a smooth flight; you just need to know what P, I, and D actually do.
Let's simplify it:
- P (Proportional): The immediate reaction. If your drone feels sluggish, raise P. If it shakes rapidly (oscillates) like it’s had too much coffee, lower P.
- I (Integral): The memory. It keeps the drone holding its angle against the wind. If your drone drifts when you let go of the sticks, your I-term might be too low.
- D (Derivative): The dampener. It smooths out the P-term. It’s like the shock absorbers on your car.
The "Blackbox" Secret: The best way to tune is to look at your Blackbox logs (yes, data logs!). But before you touch any software, check your hardware. A loose arm or a vibrating motor cannot be fixed with PIDs.
Ensure your build is mechanically sound first. A stiff, high-quality s the foundation of a well-tuned quad.